ZED-F9R is a satellite-navigation receiver that processes GNSS signals to determine position and timing. It supplies navigation information to a host installation, with antenna selection and correction services defined by the required positioning performance.
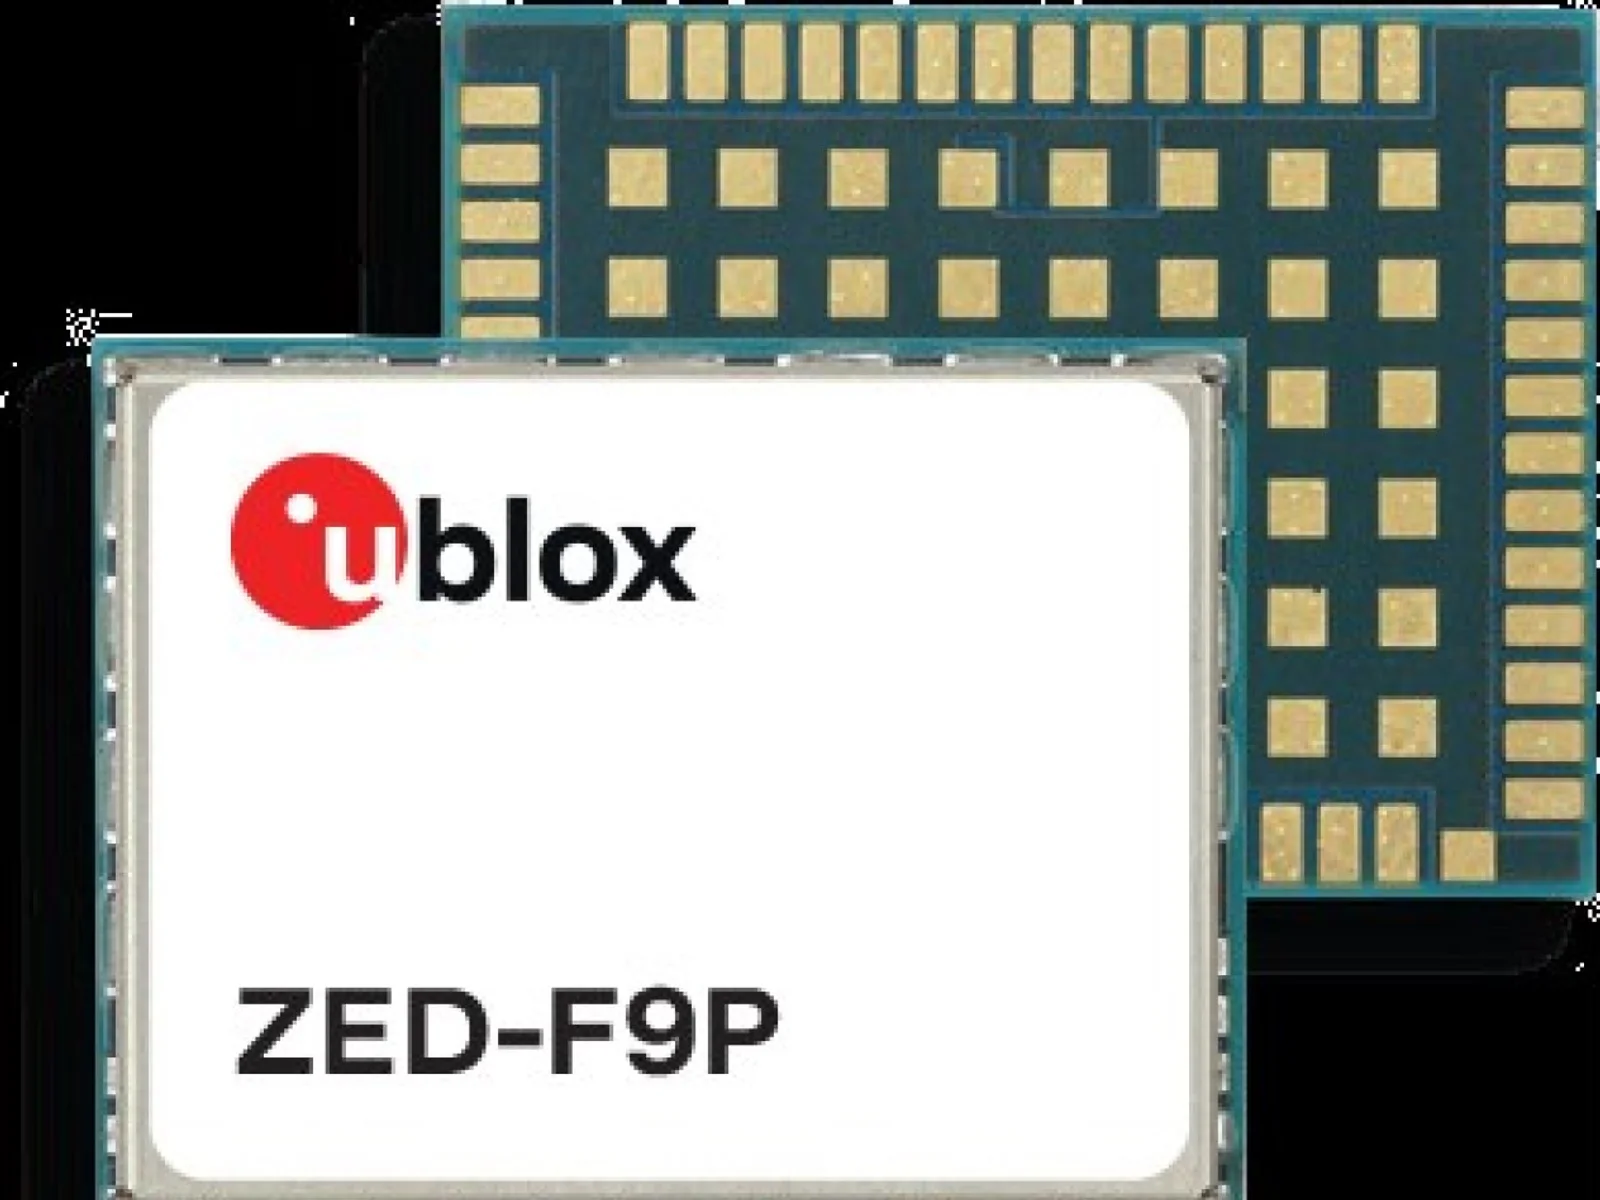
The ZED-F9R is a high-precision sensor-fusion GNSS receiver module from u-blox, combining a multi-band satellite-navigation receiver with an integrated inertial measurement unit (IMU) in a surface-mount LGA package of 17.0 x 22.0 x 2.4 mm. The ZED-F9R-04B variant described by the datasheet is a professional-grade GPS receiver module for applications that need centimetre-level RTK positioning and continued position output when satellite signals are lost.
The receiver tracks GPS and QZSS (L1 C/A and L2C), GLONASS (L1OF and L2OF), Galileo (E1-B/C and E5b) and BeiDou (B1I and B2I) simultaneously, and also receives SBAS. For integrators, the two bands per constellation allow RTK and PPP-RTK solutions and faster convergence. The datasheet lists a horizontal accuracy of 1.5 m CEP for standalone PVT, 1.0 m with SBAS and 0.01 m + 1 ppm in RTK mode, with RTK re-convergence in 10 s or less. With SPARTN corrections the horizontal accuracy is below 0.06 m, and with CLAS it is 0.04 m. The maximum navigation update rate in RTK is 30 Hz in priority navigation mode and 4 Hz otherwise, with a navigation latency of 15 ms in priority mode, and sensor measurements can be output at up to 100 Hz. The operational limits are 4 g dynamics, 80,000 m altitude and 500 m/s velocity, with the airborne 4 g platform as the basis of the limits. Dynamic attitude accuracy is 0.2 deg for heading, 0.3 deg for pitch and 0.5 deg for roll.
The IMU is fused with the GNSS measurements, with wheel-tick input and a dynamic model, so the module can bridge short outages. The datasheet quotes a position error of 2 percent of the distance travelled during GNSS loss, a value which applies to a four-wheel road vehicle. The fusion algorithm is optimised for automotive, e-scooter, robotic lawn mower and rail platforms, so integrators who use it on aircraft should check the behaviour of the dynamic model for their vehicle.
Interfaces and power are straightforward. The module is supplied with 2.7 to 3.6 V (3.0 V typical), and a separate backup supply of 1.65 to 3.6 V keeps the data for hot starts. Communication goes through UART, USB, SPI and I2C. The supported protocols are UBX (the u-blox binary protocol), NMEA 4.11 as default, and RTCM 3.4 and SPARTN 2.0.2 as correction inputs. The module accepts RTCM messages for RTK and DGNSS, and the CLAS correction service is supported. The operating temperature is -40 to 85 degrees C.
Security features include jamming and spoofing detection and reporting, signed messages with SHA-256, secure boot and configuration lockdown. The GNSS chips are qualified according to AEC-Q100 and are manufactured at ISO/TS 16949 certified sites, with qualification tests following ISO16750.
Typical applications are precise positioning of ground robots, automotive and rail systems, and uncrewed aircraft where an RTK position with high update rate and an integrated IMU are needed in one small module.
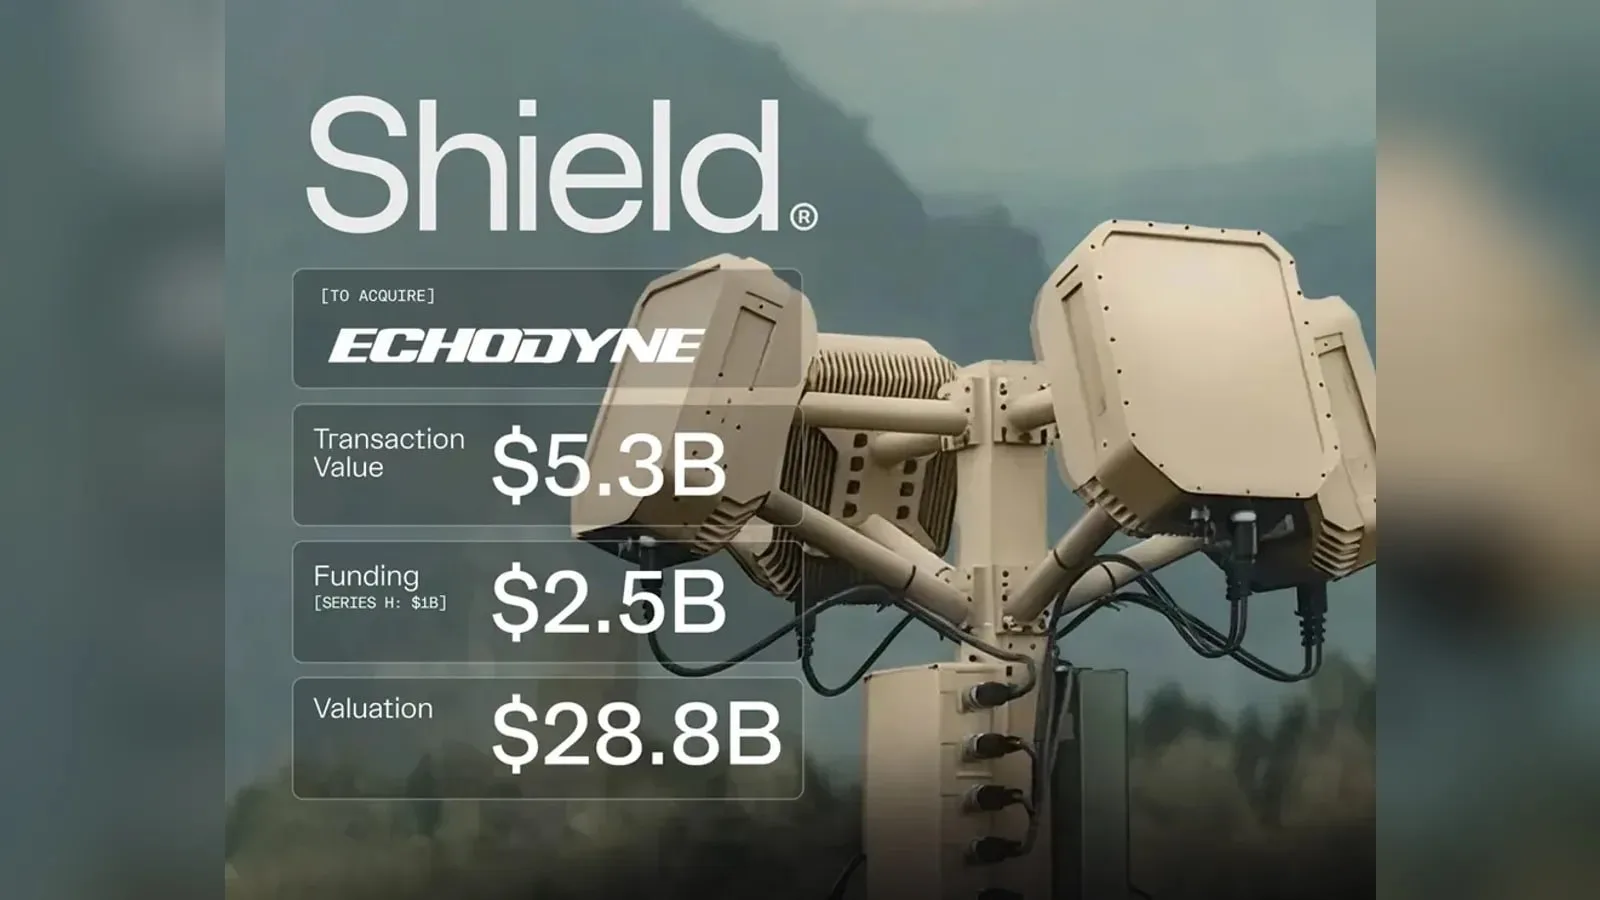
Shield agrees to buy Echodyne, the Kirkland-based radar maker, in a deal valued at $5.3 billion. The purchase brings software-defined MESA radars, used in counter-UAS systems and for UAS detect-and-avoid, into Shield's Mission Systems…
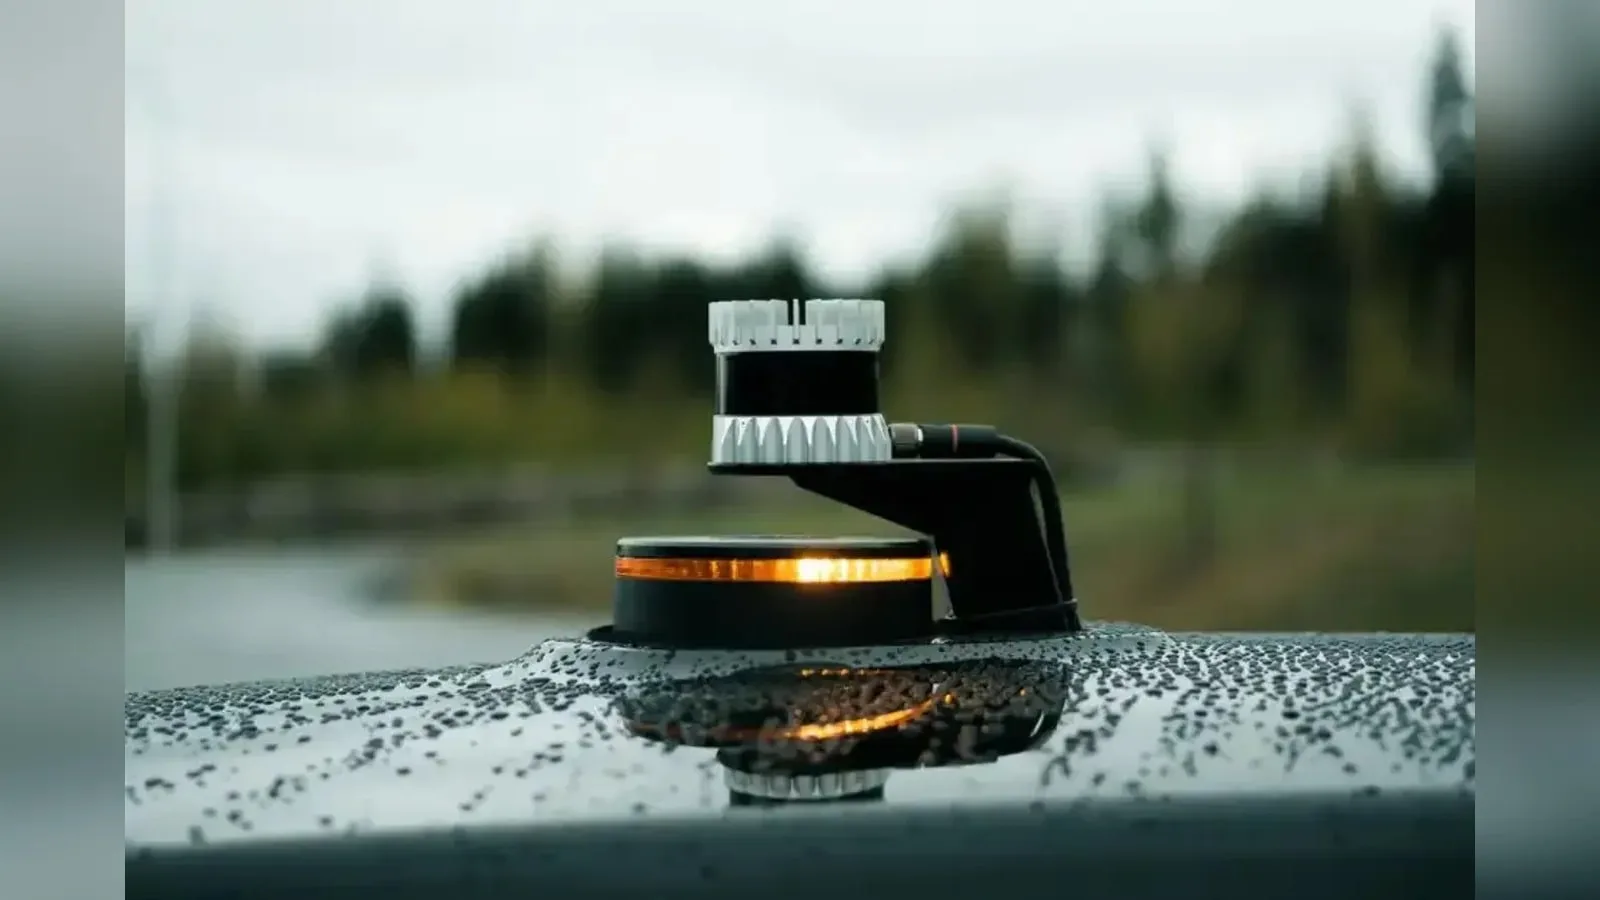
Ouster releases Firmware 3.2 for its lidar sensors, adding on-sensor 3D zone monitoring, optical window blockage detection and time-synchronized IMU data. The update shifts occupancy logic and motion compensation from the host computer to…
Shield has agreed to buy Echodyne, the Washington-based maker of MESA radars for counter-UAS and airspace sensing, for $5.3bn. Echodyne's radars stay available as standalone products, and the deal adds production capacity for the sensor…




 FeaturedGNSS receivers
 Featured
 FeaturedGNSS receivers
 FeaturedGNSS receivers
 FeaturedGNSS receivers
 FeaturedGNSS receivers